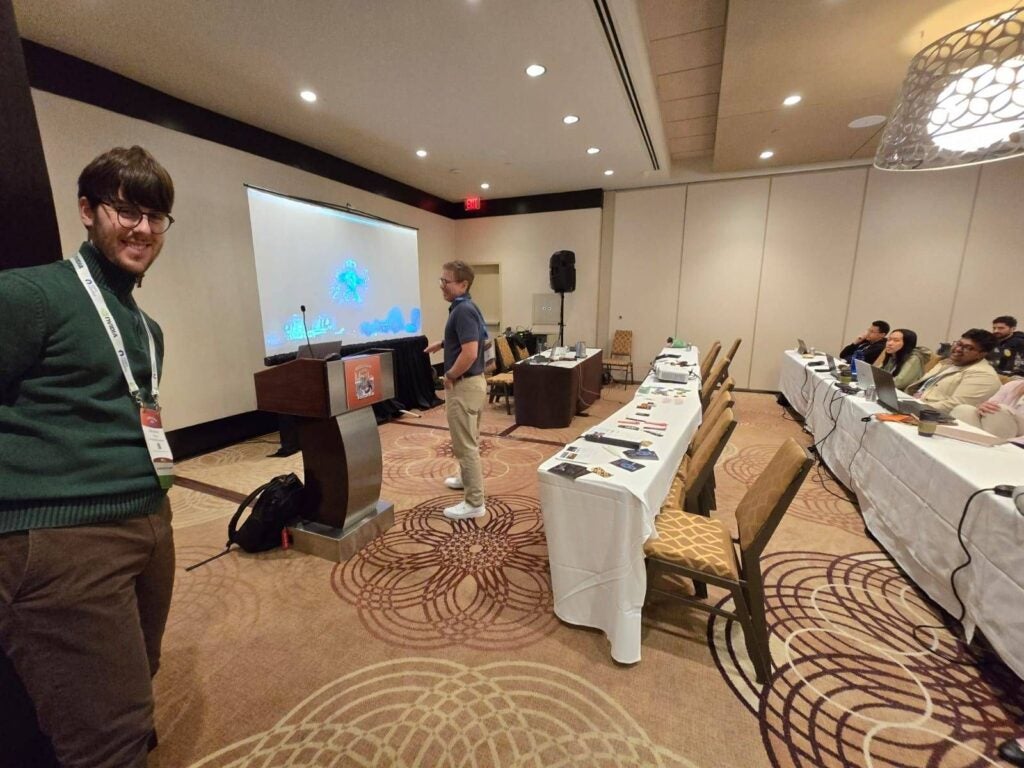
 ROSCon Global came to Toronto from September 22 to 24, and the aerial robotics community packed its first day. Dronecode ran a full-day PX4 and ROS 2 workshop that morning and sponsored the Aerial Robotics Meetup that evening, building on the bridge between the PX4 and ROS communities that we are continuing from our involvement in the Singapore show last year.
Advanced Aerial Robotics Workshop
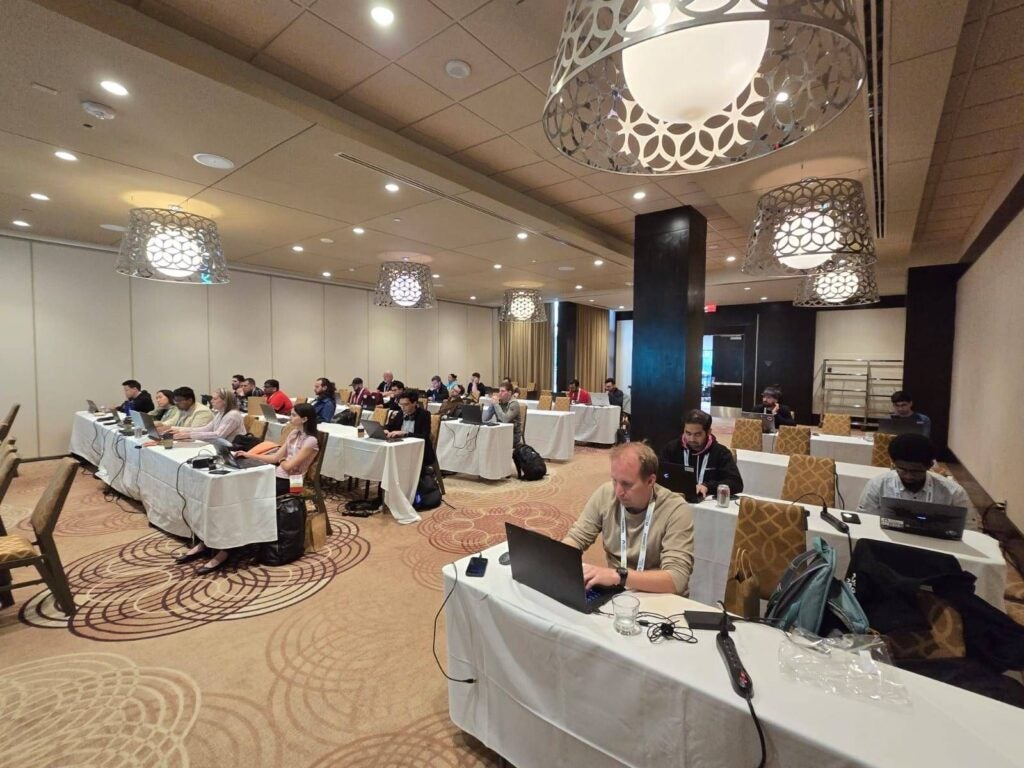 Our community members presented a full-day workshop, “Advanced Aerial Robotics with PX4 and ROS 2: Custom Flight Modes and Beyond,” picked up where last year’s introductory session left off. These workshops are becoming a bit of a tradition, and we are proud to see them continuing. Participants built custom flight modes and sequenced complex autonomous behaviors for aerial robots entirely in ROS 2, with PX4 running the flight control underneath.
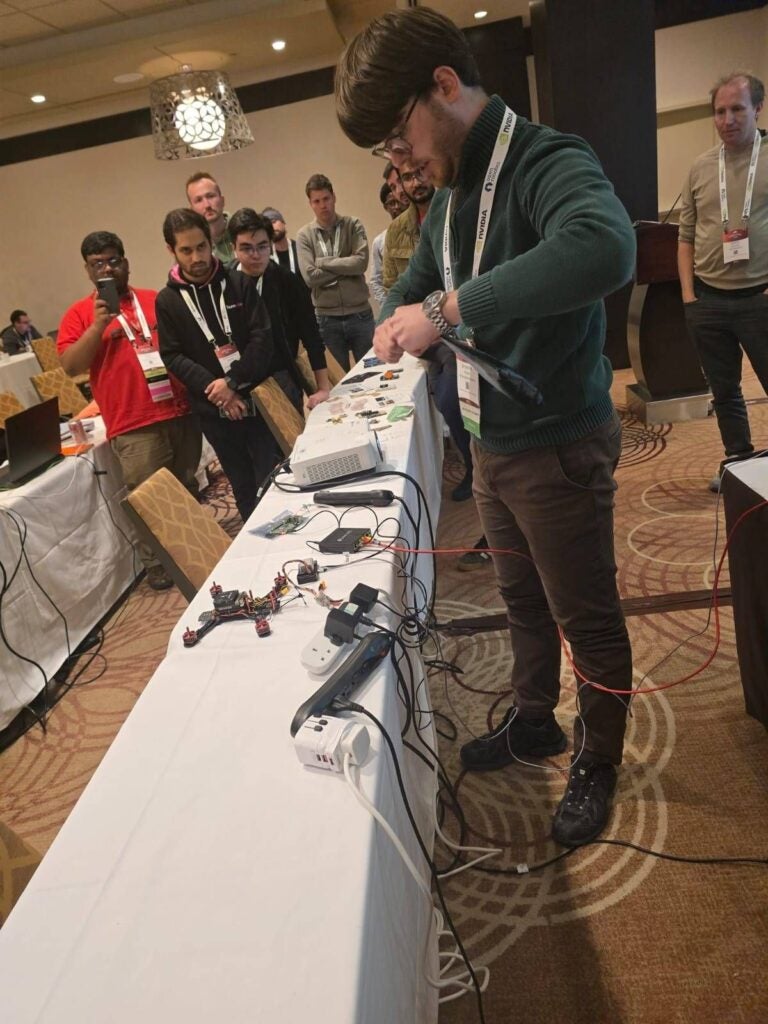 Beniamino Pozzan of Archangel Autonomy and Patrik Dominik Pördi of the University of Southern Denmark built the content and delivered it to a packed room. Thank you both for the work that went into it.
Aerial Robotics Meetup
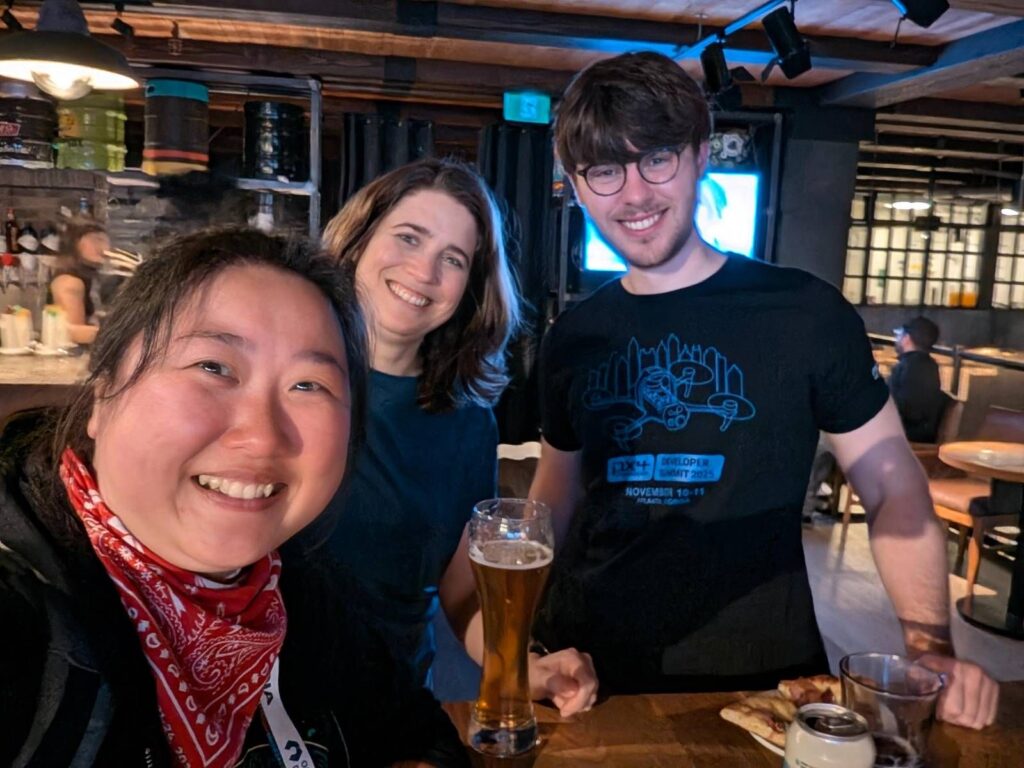 That evening, the Aerial Robotics Community Group hosted the Aerial Robotics Meetup @ ROSCon Global 2026 at CRAFT Beer Market Toronto, and Dronecode sponsored the venue, food, and drinks. Developers, researchers, and aerial robotics engineers spent three hours talking through ROS 2 integrations, control architectures, state estimation, and the open source collaborations coming up across the ecosystem.
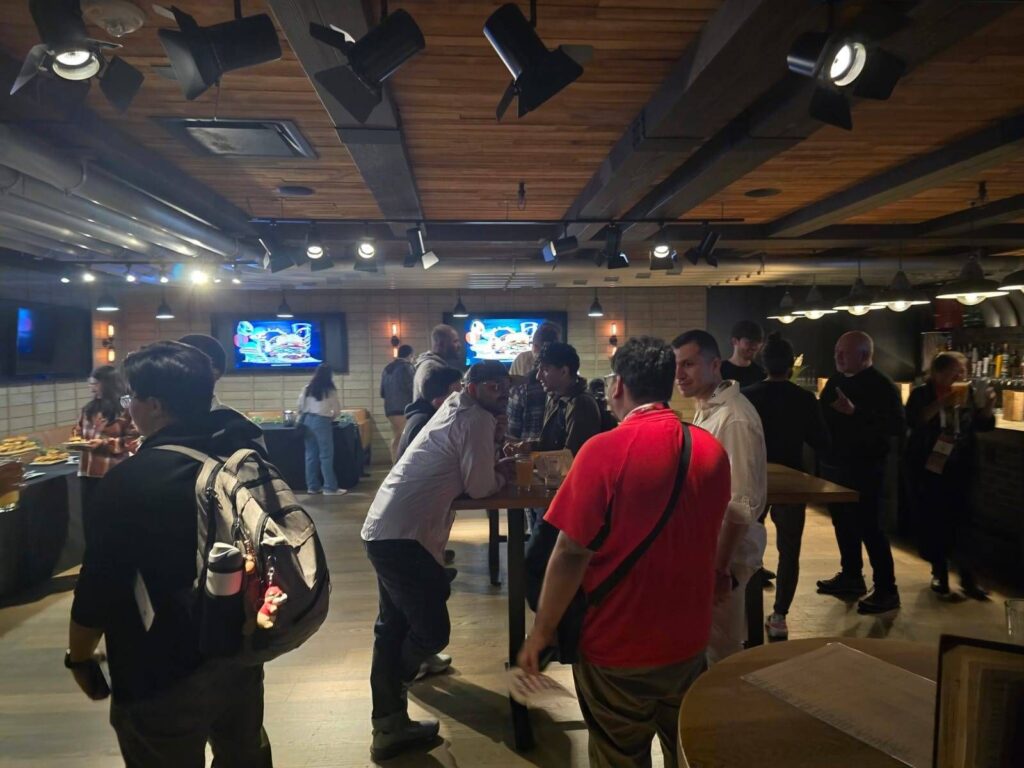 Thank you to the Aerial Robotics Community Group for organizing the meetup, and to Open Robotics for supporting the community’s events around ROSCon.
 Looking Ahead
This was our second year bringing a PX4 workshop to ROSCon, and each year the conversation between the PX4 and ROS communities gets deeper. We can’t wait to see how we will collaborate together for ROSCon in Kraków next year.
If you want to keep building with PX4 and ROS 2 between conferences, join us on the Dronecode Discord.
Thank you to everyone who joined us in Toronto.